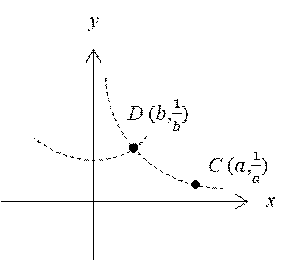+3점 · [1] 회전변환 f \displaystyle f f g \displaystyle g g A , B \displaystyle A,~B A , B 합성변환 h = g ∘ f \displaystyle h=g\circ f h = g ∘ f H = B A \displaystyle H=BA H = B A A = ( cos π 4 − sin π 4 sin π 4 cos π 4 ) = ( 1 2 − 1 2 1 2 1 2 ) , B = ( 1 2 0 0 1 2 ) \displaystyle A= \begin{pmatrix} \cos \frac{\pi}{4} &~-\sin \frac{\pi}{4} \\ \sin \frac{\pi}{4}& ~\cos \frac{\pi}{4} \end{pmatrix} = \begin{pmatrix} \frac{1}{\sqrt 2} & - \frac{1}{\sqrt 2} \\ \frac{1}{\sqrt 2} &\frac{1}{\sqrt 2} \end{pmatrix}, B= \begin{pmatrix} \frac{1}{\sqrt 2} & 0\\ 0& \frac{1}{\sqrt 2} \end{pmatrix} A = ( cos 4 π sin 4 π − sin 4 π cos 4 π ) = ( 2 1 2 1 − 2 1 2 1 ) , B = ( 2 1 0 0 2 1 ) H = ( 1 2 − 1 2 1 2 1 2 ) = 1 2 ( 1 − 1 1 1 ) \displaystyle H=\begin{pmatrix}\frac12&-\frac12\\\frac12&\frac12\end{pmatrix}=\frac12\begin{pmatrix}1&-1\\1&1\end{pmatrix} H = ( 2 1 2 1 − 2 1 2 1 ) = 2 1 ( 1 1 − 1 1 ) [1]
회전변환 f \displaystyle f f g \displaystyle g g A , B \displaystyle A,~B A , B
합성변환 h = g ∘ f \displaystyle h=g\circ f h = g ∘ f H = B A \displaystyle H=BA H = B A
A = ( cos π 4 − sin π 4 sin π 4 cos π 4 ) = ( 1 2 − 1 2 1 2 1 2 ) , B = ( 1 2 0 0 1 2 ) \displaystyle A= \begin{pmatrix} \cos \frac{\pi}{4} &~-\sin \frac{\pi}{4} \\ \sin \frac{\pi}{4}& ~\cos \frac{\pi}{4} \end{pmatrix} = \begin{pmatrix} \frac{1}{\sqrt 2} & - \frac{1}{\sqrt 2} \\ \frac{1}{\sqrt 2} &\frac{1}{\sqrt 2} \end{pmatrix}, B= \begin{pmatrix} \frac{1}{\sqrt 2} & 0\\ 0& \frac{1}{\sqrt 2} \end{pmatrix} A = ( cos 4 π sin 4 π − sin 4 π cos 4 π ) = ( 2 1 2 1 − 2 1 2 1 ) , B = ( 2 1 0 0 2 1 )
H = ( 1 2 − 1 2 1 2 1 2 ) = 1 2 ( 1 − 1 1 1 ) \displaystyle H=\begin{pmatrix}\frac12&-\frac12\\\frac12&\frac12\end{pmatrix}=\frac12\begin{pmatrix}1&-1\\1&1\end{pmatrix} H = ( 2 1 2 1 − 2 1 2 1 ) = 2 1 ( 1 1 − 1 1 )
+6점 · 한편, 원점을 중심으로 각 θ \displaystyle \theta θ F \displaystyle F F k \displaystyle k k G \displaystyle G G F = ( cos θ − sin θ sin θ cos θ ) , G = ( k 0 0 k ) \displaystyle F=\begin{pmatrix}\cos\theta&-\sin\theta\\\sin\theta&\cos\theta\end{pmatrix},~G=\begin{pmatrix}k&0\\0&k\end{pmatrix} F = ( cos θ sin θ − sin θ cos θ ) , G = ( k 0 0 k ) F n = ( cos n θ − sin n θ sin n θ cos n θ ) , G n = ( k n 0 0 k n ) \displaystyle F^n=\begin{pmatrix}\cos n\theta&-\sin n\theta\\\sin n\theta&\cos n\theta\end{pmatrix},~G^n=\begin{pmatrix}k^n&0\\0&k^n\end{pmatrix} F n = ( cos n θ sin n θ − sin n θ cos n θ ) , G n = ( k n 0 0 k n ) 따라서 변환 h \displaystyle h h n \displaystyle n n h n \displaystyle h^n h n H n = ( B A ) n = B n A n \displaystyle H^n=(BA)^n=B^nA^n H n = ( B A ) n = B n A n H n = B n A n = ( 1 2 0 0 1 2 ) n ( cos π 4 − sin π 4 sin π 4 cos π 4 ) n \displaystyle H^n = B^n A^n ={\begin{pmatrix} \frac{1}{\sqrt 2} & 0\\ 0& \frac{1}{\sqrt 2} \end{pmatrix}}^n { \begin{pmatrix} \cos \frac{\pi}{4} &~-\sin \frac{\pi}{4} \\ \sin \frac{\pi}{4}& ~\cos \frac{\pi}{4}\end{pmatrix} }^n H n = B n A n = ( 2 1 0 0 2 1 ) n ( cos 4 π sin 4 π − sin 4 π cos 4 π ) n = ( ( 1 2 ) n 0 0 ( 1 2 ) n ) ( cos n 4 π − sin n 4 π sin n 4 π cos n 4 π ) \displaystyle =\begin{pmatrix}(\frac1{\sqrt2})^n&0\\0&(\frac1{\sqrt2})^n\end{pmatrix}\begin{pmatrix}\cos\frac n4\pi&-\sin\frac n4\pi\\\sin\frac n4\pi&\cos\frac n4\pi\end{pmatrix} = ( ( 2 1 ) n 0 0 ( 2 1 ) n ) ( cos 4 n π sin 4 n π − sin 4 n π cos 4 n π ) = ( 1 2 ) n ( cos n 4 π − sin n 4 π sin n 4 π cos n 4 π ) \displaystyle = \left ( \frac{1}{\sqrt 2} \right )^n { \begin{pmatrix} \cos \frac{n}{4} \pi &~-\sin \frac{n}{4} \pi \\ \sin \frac{n}{4} \pi & ~\cos \frac{n}{4} \pi \end{pmatrix} } = ( 2 1 ) n ( cos 4 n π sin 4 n π − sin 4 n π cos 4 n π ) 단, 회전행렬 F n \displaystyle F^n F n H n \displaystyle H^n H n 한편, 원점을 중심으로 각 θ \displaystyle \theta θ F \displaystyle F F k \displaystyle k k G \displaystyle G G
F = ( cos θ − sin θ sin θ cos θ ) , G = ( k 0 0 k ) \displaystyle F=\begin{pmatrix}\cos\theta&-\sin\theta\\\sin\theta&\cos\theta\end{pmatrix},~G=\begin{pmatrix}k&0\\0&k\end{pmatrix} F = ( cos θ sin θ − sin θ cos θ ) , G = ( k 0 0 k ) F n = ( cos n θ − sin n θ sin n θ cos n θ ) , G n = ( k n 0 0 k n ) \displaystyle F^n=\begin{pmatrix}\cos n\theta&-\sin n\theta\\\sin n\theta&\cos n\theta\end{pmatrix},~G^n=\begin{pmatrix}k^n&0\\0&k^n\end{pmatrix} F n = ( cos n θ sin n θ − sin n θ cos n θ ) , G n = ( k n 0 0 k n )
따라서 변환 h \displaystyle h h n \displaystyle n n h n \displaystyle h^n h n H n = ( B A ) n = B n A n \displaystyle H^n=(BA)^n=B^nA^n H n = ( B A ) n = B n A n
H n = B n A n = ( 1 2 0 0 1 2 ) n ( cos π 4 − sin π 4 sin π 4 cos π 4 ) n \displaystyle H^n = B^n A^n ={\begin{pmatrix} \frac{1}{\sqrt 2} & 0\\ 0& \frac{1}{\sqrt 2} \end{pmatrix}}^n { \begin{pmatrix} \cos \frac{\pi}{4} &~-\sin \frac{\pi}{4} \\ \sin \frac{\pi}{4}& ~\cos \frac{\pi}{4}\end{pmatrix} }^n H n = B n A n = ( 2 1 0 0 2 1 ) n ( cos 4 π sin 4 π − sin 4 π cos 4 π ) n
= ( ( 1 2 ) n 0 0 ( 1 2 ) n ) ( cos n 4 π − sin n 4 π sin n 4 π cos n 4 π ) \displaystyle =\begin{pmatrix}(\frac1{\sqrt2})^n&0\\0&(\frac1{\sqrt2})^n\end{pmatrix}\begin{pmatrix}\cos\frac n4\pi&-\sin\frac n4\pi\\\sin\frac n4\pi&\cos\frac n4\pi\end{pmatrix} = ( ( 2 1 ) n 0 0 ( 2 1 ) n ) ( cos 4 n π sin 4 n π − sin 4 n π cos 4 n π )
= ( 1 2 ) n ( cos n 4 π − sin n 4 π sin n 4 π cos n 4 π ) \displaystyle = \left ( \frac{1}{\sqrt 2} \right )^n { \begin{pmatrix} \cos \frac{n}{4} \pi &~-\sin \frac{n}{4} \pi \\ \sin \frac{n}{4} \pi & ~\cos \frac{n}{4} \pi \end{pmatrix} } = ( 2 1 ) n ( cos 4 n π sin 4 n π − sin 4 n π cos 4 n π )
+2점 · [2] 역변환 h − 1 \displaystyle h^{-1} h − 1 H − 1 = ( 1 2 − 1 2 1 2 1 2 ) − 1 = ( 1 1 − 1 1 ) \displaystyle H^{-1} = {\begin{pmatrix} \frac{1}{2} &- \frac{1}{2} \\ \frac{1}{2} & ~~\frac{1}{2}\end{pmatrix} }^{-1} = \begin{pmatrix} ~1& ~1\\ -1& ~1\end{pmatrix} H − 1 = ( 2 1 2 1 − 2 1 2 1 ) − 1 = ( 1 − 1 1 1 ) [2] 역변환 h − 1 \displaystyle h^{-1} h − 1 H − 1 = ( 1 2 − 1 2 1 2 1 2 ) − 1 = ( 1 1 − 1 1 ) \displaystyle H^{-1} = {\begin{pmatrix} \frac{1}{2} &- \frac{1}{2} \\ \frac{1}{2} & ~~\frac{1}{2}\end{pmatrix} }^{-1} = \begin{pmatrix} ~1& ~1\\ -1& ~1\end{pmatrix} H − 1 = ( 2 1 2 1 − 2 1 2 1 ) − 1 = ( 1 − 1 1 1 )
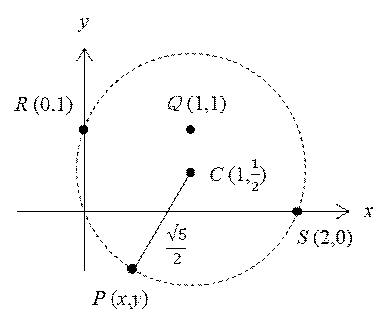
+3점 · 점 Q ( 1 , 1 ) \displaystyle \mathrm{Q}(1,1) Q ( 1 , 1 ) h ( Q ) = ( 1 2 − 1 2 1 2 1 2 ) ( 1 1 ) = ( 0 1 ) \displaystyle h(\mathrm{Q})=\begin{pmatrix}\frac12&-\frac12\\\frac12&\frac12\end{pmatrix}\begin{pmatrix}1\\1\end{pmatrix}=\begin{pmatrix}0\\1\end{pmatrix} h ( Q ) = ( 2 1 2 1 − 2 1 2 1 ) ( 1 1 ) = ( 0 1 ) h − 1 ( Q ) = ( 1 1 − 1 1 ) ( 1 1 ) = ( 2 0 ) \displaystyle h^{-1}(\mathrm{Q})=\begin{pmatrix}1&1\\-1&1\end{pmatrix}\begin{pmatrix}1\\1\end{pmatrix}=\begin{pmatrix}2\\0\end{pmatrix} h − 1 ( Q ) = ( 1 − 1 1 1 ) ( 1 1 ) = ( 2 0 ) h \displaystyle h h h − 1 \displaystyle h^{-1} h − 1 R ( 0 , 1 ) , S ( 2 , 0 ) \displaystyle \mathrm{R}(0,1 ) ,~ \mathrm{S}(2,0 ) R ( 0 , 1 ) , S ( 2 , 0 ) 점 Q ( 1 , 1 ) \displaystyle \mathrm{Q}(1,1) Q ( 1 , 1 ) h ( Q ) = ( 1 2 − 1 2 1 2 1 2 ) ( 1 1 ) = ( 0 1 ) \displaystyle h(\mathrm{Q})=\begin{pmatrix}\frac12&-\frac12\\\frac12&\frac12\end{pmatrix}\begin{pmatrix}1\\1\end{pmatrix}=\begin{pmatrix}0\\1\end{pmatrix} h ( Q ) = ( 2 1 2 1 − 2 1 2 1 ) ( 1 1 ) = ( 0 1 ) h − 1 ( Q ) = ( 1 1 − 1 1 ) ( 1 1 ) = ( 2 0 ) \displaystyle h^{-1}(\mathrm{Q})=\begin{pmatrix}1&1\\-1&1\end{pmatrix}\begin{pmatrix}1\\1\end{pmatrix}=\begin{pmatrix}2\\0\end{pmatrix} h − 1 ( Q ) = ( 1 − 1 1 1 ) ( 1 1 ) = ( 2 0 )
변환 h \displaystyle h h h − 1 \displaystyle h^{-1} h − 1 R ( 0 , 1 ) , S ( 2 , 0 ) \displaystyle \mathrm{R}(0,1 ) ,~ \mathrm{S}(2,0 ) R ( 0 , 1 ) , S ( 2 , 0 )
+4점 · 따라서, 평면 위의 점 P ( x , y ) \displaystyle \mathrm{P}(x,y) P ( x , y ) P R → , P S → \displaystyle \overrightarrow{\mathrm{PR}},~\overrightarrow{\mathrm{PS}} PR , PS P R → = O R → − O P → = ( − x , 1 − y ) , P S → = O S → − O P → = ( 2 − x , − y ) \displaystyle \overrightarrow{\mathrm{PR}} = \overrightarrow{\mathrm{OR}} - \overrightarrow{\mathrm{OP}} = (-x, 1-y) ,~ \overrightarrow{\mathrm{PS}} = \overrightarrow{\mathrm{OS}} - \overrightarrow{\mathrm{OP}} = (2-x, -y) PR = OR − OP = ( − x , 1 − y ) , PS = OS − OP = ( 2 − x , − y ) 따라서, 평면 위의 점 P ( x , y ) \displaystyle \mathrm{P}(x,y) P ( x , y ) P R → , P S → \displaystyle \overrightarrow{\mathrm{PR}},~\overrightarrow{\mathrm{PS}} PR , PS
P R → = O R → − O P → = ( − x , 1 − y ) , P S → = O S → − O P → = ( 2 − x , − y ) \displaystyle \overrightarrow{\mathrm{PR}} = \overrightarrow{\mathrm{OR}} - \overrightarrow{\mathrm{OP}} = (-x, 1-y) ,~ \overrightarrow{\mathrm{PS}} = \overrightarrow{\mathrm{OS}} - \overrightarrow{\mathrm{OP}} = (2-x, -y) PR = OR − OP = ( − x , 1 − y ) , PS = OS − OP = ( 2 − x , − y )
+2점 · 두 벡터의 내적 P R → ⋅ P S → = x ( x − 2 ) + y ( y − 1 ) = 0 \displaystyle \overrightarrow{\mathrm{PR}} \cdot \overrightarrow{\mathrm{PS}} = x(x-2) + y(y-1) = 0 PR ⋅ PS = x ( x − 2 ) + y ( y − 1 ) = 0 ( x − 1 ) 2 + ( y − 1 2 ) 2 = 5 4 \displaystyle (x-1 )^{2} + \left ( y- \frac{1}{2} \right )^{2} = \frac{5}{4} ( x − 1 ) 2 + ( y − 2 1 ) 2 = 4 5 P \displaystyle \mathrm{P} P C ( 1 , 1 2 ) \displaystyle \mathrm{C} \left ( 1, \frac{1}{2} \right ) C ( 1 , 2 1 ) 5 2 \displaystyle \frac{\sqrt 5}{2} 2 5 5 π \displaystyle \sqrt 5 \pi 5 π 두 벡터의 내적 P R → ⋅ P S → = x ( x − 2 ) + y ( y − 1 ) = 0 \displaystyle \overrightarrow{\mathrm{PR}} \cdot \overrightarrow{\mathrm{PS}} = x(x-2) + y(y-1) = 0 PR ⋅ PS = x ( x − 2 ) + y ( y − 1 ) = 0 ( x − 1 ) 2 + ( y − 1 2 ) 2 = 5 4 \displaystyle (x-1 )^{2} + \left ( y- \frac{1}{2} \right )^{2} = \frac{5}{4} ( x − 1 ) 2 + ( y − 2 1 ) 2 = 4 5
따라서 점 P \displaystyle \mathrm{P} P C ( 1 , 1 2 ) \displaystyle \mathrm{C} \left ( 1, \frac{1}{2} \right ) C ( 1 , 2 1 ) 5 2 \displaystyle \frac{\sqrt 5}{2} 2 5 5 π \displaystyle \sqrt 5 \pi 5 π
+5점 · [3]
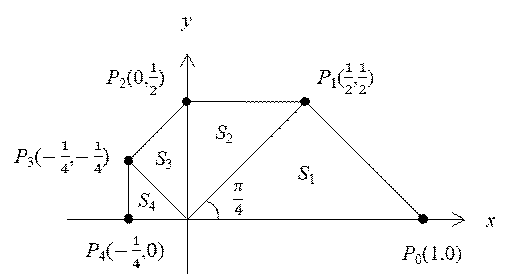
변환 h \displaystyle h h π 4 \displaystyle \frac\pi4 4 π 1 2 \displaystyle \frac1{\sqrt2} 2 1 h \displaystyle h h P n − 1 \displaystyle \mathrm{P}_{n-1} P n − 1 P n \displaystyle \mathrm{P}_n P n O P n − 1 → , O P n → \displaystyle \overrightarrow{\mathrm{OP}_{n-1}},~\overrightarrow{\mathrm{OP}_n} OP n − 1 , OP n O P n → \displaystyle \overrightarrow{\mathrm{OP}_n} OP n ∣ O P n → ∣ = 1 2 ∣ O P n − 1 → ∣ \displaystyle |\overrightarrow{\mathrm{OP}_n}|=\frac1{\sqrt2}|\overrightarrow{\mathrm{OP}_{n-1}}| ∣ OP n ∣ = 2 1 ∣ OP n − 1 ∣ O P n → \displaystyle \overrightarrow{\mathrm{OP}_n} OP n O P n − 1 → \displaystyle \overrightarrow{\mathrm{OP}_{n-1}} OP n − 1 π 4 \displaystyle \frac\pi4 4 π [3]
변환 h \displaystyle h h π 4 \displaystyle \frac\pi4 4 π 1 2 \displaystyle \frac1{\sqrt2} 2 1
변환 h \displaystyle h h P n − 1 \displaystyle \mathrm{P}_{n-1} P n − 1 P n \displaystyle \mathrm{P}_n P n O P n − 1 → , O P n → \displaystyle \overrightarrow{\mathrm{OP}_{n-1}},~\overrightarrow{\mathrm{OP}_n} OP n − 1 , OP n
위치벡터 O P n → \displaystyle \overrightarrow{\mathrm{OP}_n} OP n ∣ O P n → ∣ = 1 2 ∣ O P n − 1 → ∣ \displaystyle |\overrightarrow{\mathrm{OP}_n}|=\frac1{\sqrt2}|\overrightarrow{\mathrm{OP}_{n-1}}| ∣ OP n ∣ = 2 1 ∣ OP n − 1 ∣
두 위치벡터 O P n → \displaystyle \overrightarrow{\mathrm{OP}_n} OP n O P n − 1 → \displaystyle \overrightarrow{\mathrm{OP}_{n-1}} OP n − 1 π 4 \displaystyle \frac\pi4 4 π
+4점 · 삼각형 O P n − 1 P n \displaystyle \mathrm{OP}_{n-1}\mathrm{P}_n OP n − 1 P n S n = 1 2 ∣ O P n − 1 → ∣ ∣ O P n → ∣ sin π 4 \displaystyle S_n=\frac12|\overrightarrow{\mathrm{OP}_{n-1}}||\overrightarrow{\mathrm{OP}_n}|\sin\frac\pi4 S n = 2 1 ∣ OP n − 1 ∣∣ OP n ∣ sin 4 π 삼각형 O P n P n + 1 \displaystyle \mathrm{OP}_n\mathrm{P}_{n+1} OP n P n + 1 S n + 1 = 1 2 ∣ O P n → ∣ ∣ O P n + 1 → ∣ sin π 4 \displaystyle S_{n+1}=\frac12|\overrightarrow{\mathrm{OP}_n}||\overrightarrow{\mathrm{OP}_{n+1}}|\sin\frac\pi4 S n + 1 = 2 1 ∣ OP n ∣∣ OP n + 1 ∣ sin 4 π S n + 1 S n = ∣ O P n + 1 → ∣ ∣ O P n − 1 → ∣ = ( 1 2 ) 2 = 1 2 \displaystyle \frac{S_{n+1}}{S_n}=\frac{|\overrightarrow{\mathrm{OP}_{n+1}}|}{|\overrightarrow{\mathrm{OP}_{n-1}}|}=\left(\frac1{\sqrt2}\right)^2=\frac12 S n S n + 1 = ∣ OP n − 1 ∣ ∣ OP n + 1 ∣ = ( 2 1 ) 2 = 2 1 삼각형 O P n − 1 P n \displaystyle \mathrm{OP}_{n-1}\mathrm{P}_n OP n − 1 P n S n = 1 2 ∣ O P n − 1 → ∣ ∣ O P n → ∣ sin π 4 \displaystyle S_n=\frac12|\overrightarrow{\mathrm{OP}_{n-1}}||\overrightarrow{\mathrm{OP}_n}|\sin\frac\pi4 S n = 2 1 ∣ OP n − 1 ∣∣ OP n ∣ sin 4 π
삼각형 O P n P n + 1 \displaystyle \mathrm{OP}_n\mathrm{P}_{n+1} OP n P n + 1 S n + 1 = 1 2 ∣ O P n → ∣ ∣ O P n + 1 → ∣ sin π 4 \displaystyle S_{n+1}=\frac12|\overrightarrow{\mathrm{OP}_n}||\overrightarrow{\mathrm{OP}_{n+1}}|\sin\frac\pi4 S n + 1 = 2 1 ∣ OP n ∣∣ OP n + 1 ∣ sin 4 π
S n + 1 S n = ∣ O P n + 1 → ∣ ∣ O P n − 1 → ∣ = ( 1 2 ) 2 = 1 2 \displaystyle \frac{S_{n+1}}{S_n}=\frac{|\overrightarrow{\mathrm{OP}_{n+1}}|}{|\overrightarrow{\mathrm{OP}_{n-1}}|}=\left(\frac1{\sqrt2}\right)^2=\frac12 S n S n + 1 = ∣ OP n − 1 ∣ ∣ OP n + 1 ∣ = ( 2 1 ) 2 = 2 1
+2점 · 따라서, 수열 { S n } \displaystyle \{S_n\} { S n } S 1 = 1 2 ∣ O P 0 → ∣ ∣ O P 1 → ∣ sin π 4 = 1 4 \displaystyle S_1=\frac12|\overrightarrow{\mathrm{OP}_0}||\overrightarrow{\mathrm{OP}_1}|\sin\frac\pi4=\frac14 S 1 = 2 1 ∣ OP 0 ∣∣ OP 1 ∣ sin 4 π = 4 1 1 2 \displaystyle \frac12 2 1 ∑ n = 1 ∞ S n = 1 4 1 − 1 2 = 1 2 \displaystyle \sum_{n=1}^\infty S_n=\frac{\frac14}{1-\frac12}=\frac12 n = 1 ∑ ∞ S n = 1 − 2 1 4 1 = 2 1 따라서, 수열 { S n } \displaystyle \{S_n\} { S n } S 1 = 1 2 ∣ O P 0 → ∣ ∣ O P 1 → ∣ sin π 4 = 1 4 \displaystyle S_1=\frac12|\overrightarrow{\mathrm{OP}_0}||\overrightarrow{\mathrm{OP}_1}|\sin\frac\pi4=\frac14 S 1 = 2 1 ∣ OP 0 ∣∣ OP 1 ∣ sin 4 π = 4 1 1 2 \displaystyle \frac12 2 1
무한급수의 합 ∑ n = 1 ∞ S n = 1 4 1 − 1 2 = 1 2 \displaystyle \sum_{n=1}^\infty S_n=\frac{\frac14}{1-\frac12}=\frac12 n = 1 ∑ ∞ S n = 1 − 2 1 4 1 = 2 1
+4점 · [4] 변환 h \displaystyle h h D ( b , 1 b ) \displaystyle \mathrm{D}(b,\frac1b) D ( b , b 1 ) h ( C ) = ( 1 2 − 1 2 1 2 1 2 ) ( a 1 a ) = ( 1 2 a − 1 2 a 1 2 a + 1 2 a ) = ( b 1 b ) \displaystyle h(\mathrm{C})=\begin{pmatrix}\frac12&-\frac12\\\frac12&\frac12\end{pmatrix}\begin{pmatrix}a\\\frac1a\end{pmatrix}=\begin{pmatrix}\frac12a-\frac1{2a}\\\frac12a+\frac1{2a}\end{pmatrix}=\begin{pmatrix}b\\\frac1b\end{pmatrix} h ( C ) = ( 2 1 2 1 − 2 1 2 1 ) ( a a 1 ) = ( 2 1 a − 2 a 1 2 1 a + 2 a 1 ) = ( b b 1 ) a \displaystyle a a b \displaystyle b b a − 1 a = 2 b , a + 1 a = 2 b \displaystyle a - \frac{1}{a} = 2b, ~ a+ \frac{1}{a} = \frac{2}{b} a − a 1 = 2 b , a + a 1 = b 2 [4]
변환 h \displaystyle h h D ( b , 1 b ) \displaystyle \mathrm{D}(b,\frac1b) D ( b , b 1 )
h ( C ) = ( 1 2 − 1 2 1 2 1 2 ) ( a 1 a ) = ( 1 2 a − 1 2 a 1 2 a + 1 2 a ) = ( b 1 b ) \displaystyle h(\mathrm{C})=\begin{pmatrix}\frac12&-\frac12\\\frac12&\frac12\end{pmatrix}\begin{pmatrix}a\\\frac1a\end{pmatrix}=\begin{pmatrix}\frac12a-\frac1{2a}\\\frac12a+\frac1{2a}\end{pmatrix}=\begin{pmatrix}b\\\frac1b\end{pmatrix} h ( C ) = ( 2 1 2 1 − 2 1 2 1 ) ( a a 1 ) = ( 2 1 a − 2 a 1 2 1 a + 2 a 1 ) = ( b b 1 )
a \displaystyle a a b \displaystyle b b a − 1 a = 2 b , a + 1 a = 2 b \displaystyle a - \frac{1}{a} = 2b, ~ a+ \frac{1}{a} = \frac{2}{b} a − a 1 = 2 b , a + a 1 = b 2
+4점 · 이에 양변을 곱하면 a 2 − 1 a 2 = 4 \displaystyle a^2-\frac1{a^2}=4 a 2 − a 2 1 = 4 a 4 − 4 a 2 − 1 = 0 \displaystyle a^4-4a^2-1=0 a 4 − 4 a 2 − 1 = 0 a 2 > 0 \displaystyle a^2>0 a 2 > 0 a 2 = 2 + 5 \displaystyle a^2=2+\sqrt5 a 2 = 2 + 5 이에 양변을 곱하면 a 2 − 1 a 2 = 4 \displaystyle a^2-\frac1{a^2}=4 a 2 − a 2 1 = 4 a 4 − 4 a 2 − 1 = 0 \displaystyle a^4-4a^2-1=0 a 4 − 4 a 2 − 1 = 0
따라서 a 2 > 0 \displaystyle a^2>0 a 2 > 0 a 2 = 2 + 5 \displaystyle a^2=2+\sqrt5 a 2 = 2 + 5
+5점 · [5]
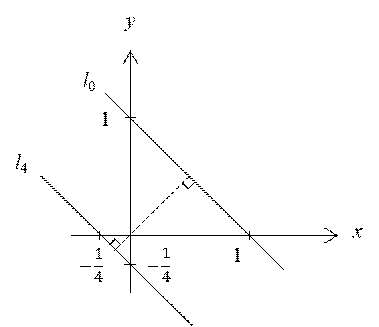
변환 h \displaystyle h h h \displaystyle h h 4 k \displaystyle 4k 4 k l 0 \displaystyle l_0 l 0 m = 4 \displaystyle m=4 m = 4 h 4 \displaystyle h^{4} h 4 H 4 = ( ( 1 2 ) 4 cos 4 4 π − ( 1 2 ) 4 sin 4 4 π ( 1 2 ) 4 sin 4 4 π ( 1 2 ) 4 cos 4 4 π ) = − 1 4 ( 1 0 0 1 ) \displaystyle H^{4} = \begin{pmatrix} \left ( \frac{1}{\sqrt 2} \right )^{4} \cos \frac{4}{4} \pi &~-\left ( \frac{1}{\sqrt 2} \right )^{4} \sin \frac{4}{4} \pi \\ \left ( \frac{1}{\sqrt 2} \right )^{4} \sin \frac{4}{4} \pi &\left ( \frac{1}{\sqrt 2} \right )^{4} \cos \frac{4}{4} \pi \end{pmatrix} = - \frac{1}{4} \begin{pmatrix} 1& ~0\\ 0 &~1 \end{pmatrix} H 4 = ( 2 1 ) 4 cos 4 4 π ( 2 1 ) 4 sin 4 4 π − ( 2 1 ) 4 sin 4 4 π ( 2 1 ) 4 cos 4 4 π = − 4 1 ( 1 0 0 1 ) [5]
변환 h \displaystyle h h h \displaystyle h h 4 k \displaystyle 4k 4 k l 0 \displaystyle l_0 l 0 m = 4 \displaystyle m=4 m = 4
이때 변환 h 4 \displaystyle h^{4} h 4 H 4 = ( ( 1 2 ) 4 cos 4 4 π − ( 1 2 ) 4 sin 4 4 π ( 1 2 ) 4 sin 4 4 π ( 1 2 ) 4 cos 4 4 π ) = − 1 4 ( 1 0 0 1 ) \displaystyle H^{4} = \begin{pmatrix} \left ( \frac{1}{\sqrt 2} \right )^{4} \cos \frac{4}{4} \pi &~-\left ( \frac{1}{\sqrt 2} \right )^{4} \sin \frac{4}{4} \pi \\ \left ( \frac{1}{\sqrt 2} \right )^{4} \sin \frac{4}{4} \pi &\left ( \frac{1}{\sqrt 2} \right )^{4} \cos \frac{4}{4} \pi \end{pmatrix} = - \frac{1}{4} \begin{pmatrix} 1& ~0\\ 0 &~1 \end{pmatrix} H 4 = ( 2 1 ) 4 cos 4 4 π ( 2 1 ) 4 sin 4 4 π − ( 2 1 ) 4 sin 4 4 π ( 2 1 ) 4 cos 4 4 π = − 4 1 ( 1 0 0 1 )
+3점 · 따라서 변환 h 4 \displaystyle h^4 h 4 l 0 \displaystyle l_0 l 0 ( x , y ) \displaystyle (x,y) ( x , y ) l 4 \displaystyle l_4 l 4 ( x ′ , y ′ ) \displaystyle (x^{\prime},y^{\prime}) ( x ′ , y ′ ) ( x ′ y ′ ) = − 1 4 ( 1 0 0 1 ) ( x y ) = ( − 1 4 x − 1 4 y ) \displaystyle \begin{pmatrix}x^{\prime}\\y^{\prime}\end{pmatrix}=-\frac14\begin{pmatrix}1&0\\0&1\end{pmatrix}\begin{pmatrix}x\\y\end{pmatrix}=\begin{pmatrix}-\frac14x\\-\frac14y\end{pmatrix} ( x ′ y ′ ) = − 4 1 ( 1 0 0 1 ) ( x y ) = ( − 4 1 x − 4 1 y ) l 4 \displaystyle l_4 l 4 4 x ′ + 4 y ′ = − 1 \displaystyle 4x^{\prime}+4y^{\prime}=-1 4 x ′ + 4 y ′ = − 1 따라서 변환 h 4 \displaystyle h^4 h 4 l 0 \displaystyle l_0 l 0 ( x , y ) \displaystyle (x,y) ( x , y ) l 4 \displaystyle l_4 l 4 ( x ′ , y ′ ) \displaystyle (x^{\prime},y^{\prime}) ( x ′ , y ′ )
( x ′ y ′ ) = − 1 4 ( 1 0 0 1 ) ( x y ) = ( − 1 4 x − 1 4 y ) \displaystyle \begin{pmatrix}x^{\prime}\\y^{\prime}\end{pmatrix}=-\frac14\begin{pmatrix}1&0\\0&1\end{pmatrix}\begin{pmatrix}x\\y\end{pmatrix}=\begin{pmatrix}-\frac14x\\-\frac14y\end{pmatrix} ( x ′ y ′ ) = − 4 1 ( 1 0 0 1 ) ( x y ) = ( − 4 1 x − 4 1 y ) l 4 \displaystyle l_4 l 4 4 x ′ + 4 y ′ = − 1 \displaystyle 4x^{\prime}+4y^{\prime}=-1 4 x ′ + 4 y ′ = − 1
+3점 · 원점으로부터 직선 l 0 \displaystyle l_0 l 0 d 0 \displaystyle d_0 d 0 d 0 = ∣ − 1 ∣ 1 2 + 1 2 = 1 2 = 2 2 \displaystyle d_0=\frac{|-1|}{\sqrt{1^2+1^2}}=\frac1{\sqrt2}=\frac{\sqrt2}2 d 0 = 1 2 + 1 2 ∣ − 1∣ = 2 1 = 2 2 l 4 \displaystyle l_4 l 4 d 4 \displaystyle d_4 d 4 d 4 = ∣ 1 ∣ 4 2 + 4 2 = 1 4 2 = 2 8 \displaystyle d_4=\frac{|1|}{\sqrt{4^2+4^2}}=\frac1{4\sqrt2}=\frac{\sqrt2}8 d 4 = 4 2 + 4 2 ∣1∣ = 4 2 1 = 8 2 d 0 + d 4 = 2 2 + 2 8 = 5 2 8 \displaystyle d_0+d_4=\frac{\sqrt2}2+\frac{\sqrt2}8=\frac{5\sqrt2}8 d 0 + d 4 = 2 2 + 8 2 = 8 5 2 원점으로부터 직선 l 0 \displaystyle l_0 l 0 d 0 \displaystyle d_0 d 0 d 0 = ∣ − 1 ∣ 1 2 + 1 2 = 1 2 = 2 2 \displaystyle d_0=\frac{|-1|}{\sqrt{1^2+1^2}}=\frac1{\sqrt2}=\frac{\sqrt2}2 d 0 = 1 2 + 1 2 ∣ − 1∣ = 2 1 = 2 2
직선 l 4 \displaystyle l_4 l 4 d 4 \displaystyle d_4 d 4 d 4 = ∣ 1 ∣ 4 2 + 4 2 = 1 4 2 = 2 8 \displaystyle d_4=\frac{|1|}{\sqrt{4^2+4^2}}=\frac1{4\sqrt2}=\frac{\sqrt2}8 d 4 = 4 2 + 4 2 ∣1∣ = 4 2 1 = 8 2
따라서 두 직선 사이의 거리는 d 0 + d 4 = 2 2 + 2 8 = 5 2 8 \displaystyle d_0+d_4=\frac{\sqrt2}2+\frac{\sqrt2}8=\frac{5\sqrt2}8 d 0 + d 4 = 2 2 + 8 2 = 8 5 2
 수리논술, 배움에서 논증의 완성까지.